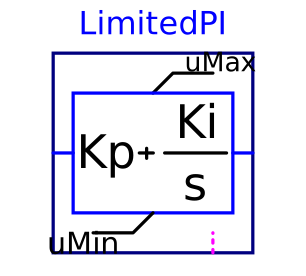
blockLimitedPI
Proportional-integrator controller with limited value of output
Extends from Modelica.Blocks.Icons.Block (Basic graphical layout of input/output block).
Information
This blocks computes y as integral of the input u multiplied by gain Ki plus input u multiplied by Kp.
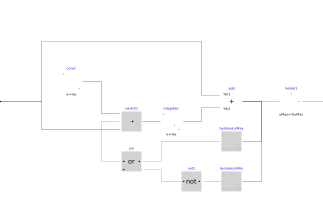
If the result reaches a given upper or lower limit, the integration is halted and only restarted if the input drives the integral away from the bounds, with a sufficient margin defined by Tol.
This margin is aimed at avoiding chattering i.e. rapid swings between frozen and unfrozen sates.
The integrator is initialized with the value Y0.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Types.PerUnit | Ki | Integrator gain | |
| Types.PerUnit | Kp | Proportional gain | |
| Types.PerUnit | Tol | 1e-5 | Tolerance on limit crossing as a fraction of the difference between limits |
| Types.PerUnit | YMax | Upper limit of output | |
| Types.PerUnit | YMin | Upper limit of output | |
| Types.PerUnit | Y0 | 0 | Initial value of output |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | u | Input signal connector | |
| Modelica.Blocks.Interfaces.RealOutput | y | Output signal connector |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Nonlinear.Limiter | limiter1 | ||
| Modelica.Blocks.Math.Add | add | ||
| Modelica.Blocks.Continuous.Integrator | integrator | ||
| Modelica.Blocks.Logical.Or | or1 | ||
| Modelica.Blocks.Logical.Hysteresis | hysteresisMax | ||
| Modelica.Blocks.Logical.Hysteresis | hysteresisMin | ||
| Modelica.Blocks.Logical.Switch | switch1 | ||
| Modelica.Blocks.Sources.Constant | const | ||
| Modelica.Blocks.Logical.Not | not1 |