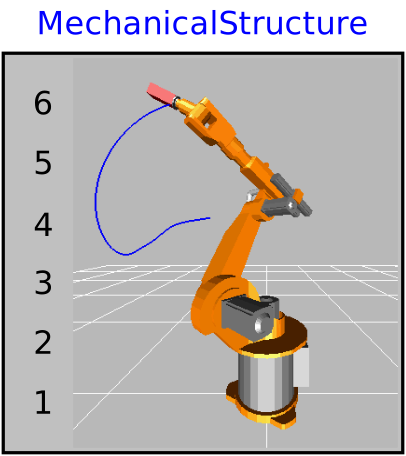
modelMechanicalStructure

Model of the mechanical part of the r3 robot (without animation)
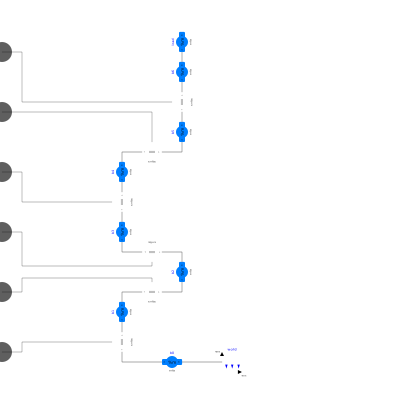
Diagram of MechanicalStructure

Information

This model contains the mechanical components of the r3 robot (multibody system).

Parameters

TypeNameDefaultDescription
Booleananimationtrue= true, if animation shall be enabled
SI.MassmLoad15Mass of load
SI.Position[3]rLoad{0, 0.25, 0}Distance from last flange to load mass
SI.Accelerationg9.81Gravity acceleration

Connectors

TypeNameDefaultDescription
Modelica.Mechanics.Rotational.Interfaces.Flange_aaxis1
Modelica.Mechanics.Rotational.Interfaces.Flange_aaxis2
Modelica.Mechanics.Rotational.Interfaces.Flange_aaxis3
Modelica.Mechanics.Rotational.Interfaces.Flange_aaxis4
Modelica.Mechanics.Rotational.Interfaces.Flange_aaxis5
Modelica.Mechanics.Rotational.Interfaces.Flange_aaxis6

Components

TypeNameDefaultDescription
SI.Angle[6]qJoint angles
SI.AngularVelocity[6]qdJoint speeds
SI.AngularAcceleration[6]qddJoint accelerations
SI.Torque[6]tauJoint driving torques
Modelica.Mechanics.MultiBody.Worldworld
Modelica.Mechanics.MultiBody.Joints.Revoluter1
Modelica.Mechanics.MultiBody.Joints.Revoluter2
Modelica.Mechanics.MultiBody.Joints.Revoluter3
Modelica.Mechanics.MultiBody.Joints.Revoluter4
Modelica.Mechanics.MultiBody.Joints.Revoluter5
Modelica.Mechanics.MultiBody.Joints.Revoluter6
Modelica.Mechanics.MultiBody.Parts.BodyShapeb0
Modelica.Mechanics.MultiBody.Parts.BodyShapeb1
Modelica.Mechanics.MultiBody.Parts.BodyShapeb2
Modelica.Mechanics.MultiBody.Parts.BodyShapeb3
Modelica.Mechanics.MultiBody.Parts.BodyShapeb4
Modelica.Mechanics.MultiBody.Parts.BodyShapeb5
Modelica.Mechanics.MultiBody.Parts.BodyShapeb6
Modelica.Mechanics.MultiBody.Parts.BodyShapeload