modelAbsoluteVelocity
Measure absolute velocity vector of origin of frame connector
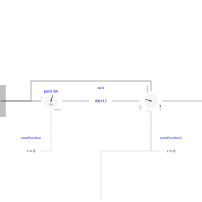
Extends from Internal.PartialAbsoluteSensor (Base class for absolute sensor models).
Information
The absolute velocity vector of the origin of frame_a is determined and provided at the output signal connector v.
Via parameter resolveInFrame it is defined, in which frame the velocity vector is resolved:
| resolveInFrame = Types.ResolveInFrameA. | Meaning |
|---|---|
| world | Resolve vector in world frame |
| frame_a | Resolve vector in frame_a |
| frame_resolve | Resolve vector in frame_resolve |
If resolveInFrame = Types.ResolveInFrameA.frame_resolve, the conditional connector "frame_resolve" is enabled and v is resolved in the frame, to which frame_resolve is connected. Note, if this connector is enabled, it must be connected.
Example
If resolveInFrame = Types.ResolveInFrameA.frame_a, the output vector is computed as:
v0 = der(frame_a.r_0);
v  = MultiBody.Frames.resolve2(frame_a.R, v0);
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Types.ResolveInFrameA | resolveInFrame | Modelica.Mechanics.MultiBody.Types.ResolveInFrameA.frame_a | Frame in which output vector v shall be resolved (world, frame_a, or frame_resolve) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Interfaces.Frame_a | frame_a (from PartialAbsoluteSensor) | Coordinate system a of which the absolute kinematic quantities are measured | |
| Blocks.Interfaces.RealOutput[3] | v | Absolute velocity vector resolved in frame defined by resolveInFrame | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_resolve | frame_resolve | Coordinate system in which output vector v is optionally resolved |