modelInverseDoublePendulum
Inverse double pendulum
Information
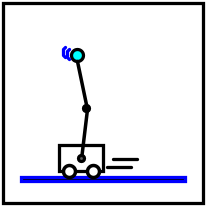
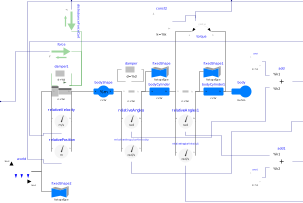
Model of a simple inverted double pendulum system. The mdel is the same as in Modelica_Controller.Examples.Components.DoublePendulum but with different initial values because the initial values are used as a working point for linearization.
The physical Model is used in Modelica_LinearSystems2.Examples.StateSpace.inverseDoublePendulumController where it is being
linearized an used as a base for linear controller design. The results are used to control the crane system
in Modelica_Controller.Examples.InverseDoublePendulum.mo
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Units.SI.Mass | m_trolley | 1 | Mass of trolley |
| Modelica.Units.SI.Mass | m_load | 1 | Mass of load on 2nd arm |
| Modelica.Units.SI.Length | length | 1 | Total length of double pendulum (i.e. length of each arm = length/2) |
| Modelica.Units.SI.Angle | phi1_start | 90.0/180*pi | Initial rotation angle of 1st arm relative to trolley |
| Modelica.Units.SI.Angle | phi2_start | 0 | Initial rotation angle of 2nd arm relative to 1st arm |
| Modelica.Units.SI.AngularVelocity | w1_start | 0.0 | Initial angular velocity of 1st arm relative to trolley |
| Modelica.Units.SI.AngularVelocity | w2_start | 0.0 | Initial angular velocity of 2nd arm relative to 1st arm |
| Modelica.Units.SI.Position | s_start | 0.0 | Initial position of trolley relative to world |
| Modelica.Units.SI.Velocity | v_start | 0.0 | Initial velocity of trolley relative to world |
| Boolean | cartDisturbance | false | True, if cart disturbance should be enabled |
| Boolean | bodyDisturbance | false | True, if body disturbance should be enabled |
| Real | pi | Modelica.Constants.pi |