modelFVController
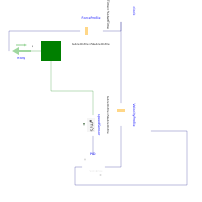
Given inputs of Force profile and desired velocity profile, controls a valve to match velocity
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Real | Td | Derivative time constant coefficient for PID controller | |
| Real | k | Proportional gain coefficient for PID controller |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealOutput | y | ||
| Modelica.Mechanics.Translational.Interfaces.Flange_a | flange_a |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.Translational.Sources.Force | force | ||
| Modelica.Blocks.Tables.CombiTable1Ds | ForceProfile | ||
| Modelica.Blocks.Sources.ContinuousClock | clock | ||
| Modelica.Mechanics.Translational.Sensors.SpeedSensor | speedSensor | ||
| Modelica.Blocks.Tables.CombiTable1Ds | VelocityProfile | ||
| Modelica.Blocks.Continuous.LimPID | PID |