modelPIcontroller4pumpexample
PI controller for pump example
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Pump Control Setting | |||
| Real | kp | 1 | Proportional Gain in the PI Controller. |
| Real | ki | 0.1 | Integrator gain in the PI Controller. |
| Real | mflow_2_speed | 188.495/585.18 | Linear gain converter from mass flow rate to motor reference speed. |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Interfaces.RealInput | m_flow_ref | ||
| Modelica.Blocks.Interfaces.RealInput | m_flow | ||
| Modelica.Blocks.Interfaces.RealOutput | Wref | Output signal connector |
Components
| Type | Name | Default | Description |
|---|---|---|---|
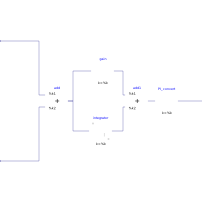
| Modelica.Blocks.Math.Add | add | ||
| Modelica.Blocks.Continuous.Integrator | integrator | ||
| Modelica.Blocks.Math.Gain | gain | ||
| Modelica.Blocks.Math.Add | add1 | ||
| Modelica.Blocks.Math.Gain | PI_convert |