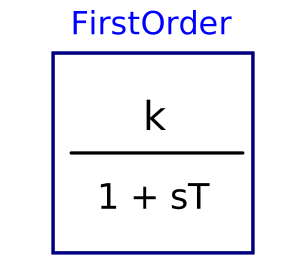
modelFirstOrder
Extends from Modelica.Blocks.Interfaces.SISO (Single Input Single Output continuous control block).
Information
Low-pass first order filter (no output limitations): y k
- = ----------------
u 1 + s*T
Neither output limitation nor anti-windup are implemented.
The dynamic parts are removed if T=0; in this case the block implements a static gain.
By default, T is a structural parameter, so it cannot be changed at runtime without recompiling the model. In order to do so, set the noDynamics parameter explicitly to false (note that you can't change T to zero at runtime in this case).
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | noDynamics | not (T > 0) | Trivial configuration with no dynamics G(s) = k |
| Real | k | 1 | Gain |
| SI.Time | T | Time Constant | |
| Initialization | |||
| Modelica.Blocks.Types.Init | initType | Modelica.Blocks.Types.Init.NoInit | Type of initialization (1: no init, 2: steady state, 3/4: initial output) |
| Real | y_start | 0 | Initial or guess value of output (= state) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| RealInput | u (from SISO) | Connector of Real input signal | |
| RealOutput | y (from SISO) | Connector of Real output signal |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Blocks.Continuous.FirstOrder | firstOrder1 | ||
| Modelica.Blocks.Math.Gain | gain |