modelAsynchronBase
Asynchronous machine base, 3-phase dq0
Extends from ACmachine (AC machine base, 3-phase dq0).
Information
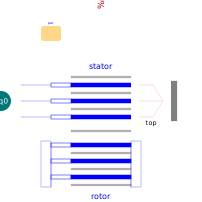
The stator contains one winding each in d-axis, q-axis, 0-axis.
The rotor contains n_r windings each in d-axis and q-axis (at least one).
See also equivalent circuit on 'Diagram layer' of
Parameters.Asynchron !
  v, i:                  stator-voltage and -current dq0
  v_rd[n_r], i_rd[n_r]:  rotor-voltage and -current d-axis
  v_rq[n_r], i_rq[n_r]:  rotor-voltage and -current q-axis
The equations are valid for all dq0 reference systems with arbitrary angular orientation.
Special choices are
  omega[2] = omega  defines 'stator' system, rotating with stator frequency
  omega[2] = w_el   defines 'rotor' system, rotating with rotor speed el (el = mec*pp)
  omega[2] = 0      defines the inertial system, not rotating.
  with
  omega[2] = der(term.theta[2])
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Integer | pp (from ACmachine) | 1 | pole-pair number |
| Data | par | machine parameters | |
| Initialization | |||
| Types.Dynamics | dynType (from ACmachine) | system.dynType | transient or steady-state model |
| PS.Current | i_start (from ACmachine) | zeros(3) | start value of current conductor |
| SI.Angle | phi_el_start (from ACmachine) | 0 | initial rotor angle electric |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Ports.ACdq0_p | term (from Port_p) | positive terminal | |
| Interfaces.Rotation_n | airgap (from ACmachine) | electro-mechanical connection | |
| Interfaces.ThermalV_n | heat (from ACmachine) | heat source port {stator, rotor} |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Topology_p | top (from YDport_p) | ||
| PS.Voltage | v (from YDport_p) | voltage conductor | |
| PS.Current | i (from YDport_p) | current conductor | |
| PS.Voltage | v_n (from YDport_p) | voltage neutral | |
| PS.Current | i_n (from YDport_p) | top.i_n | current neutral to ground |
| SI.Angle | phi_el (from ACmachine) | rotor angle electric (syn: +pi/2) | |
| SI.AngularVelocity | w_el (from ACmachine) | rotor angular velocity el | |
| SI.Torque | tau_el (from ACmachine) | electromagnetic torque | |
| Real | slip | <0: motor, >0: generator |
Contents
| Name | Description |
|---|---|
 Data | machine parameters |