modelZ_matrixEqCirc3
z-matrix from equivalent circuit, n=3
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
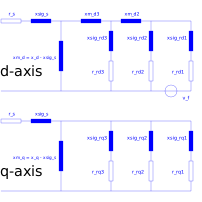
Equivalent circuit on diagram layer!
Test generator, transient order = 3.
Circuit data are:
  {r[1:n], r_0} = {0.0011, 0.012, 0.03, 0.005},     d- and q-axis
  {xsig[1:n], xsig_0} = {0.13, 0.035, 0.001, 0.17}, d- and q-axis
  {xm[1:n], xm_0} = {0, 0.02, 0.04, 1.6}, d-axis (coupling terms xm[2:3])
  {xm[1:n], xm_0} = {0, 0, 0, 1.6},       d-axis (coupling terms zero)
Corresponding transient data are:
  tc_d  = {0.869154751730285, 0.028837675377106,  0.00293370131083294} d-axis
  to_d  = {4.79391852025869,  0.0390156982688014, 0.00331427152151774} d-axis
  xtr_d = {0.324237799805601, 0.238193407852477,  0.209956053815068}   d-axis

  tc_q  = {0.710852334653427, 0.0267828156988275, 0.00180497772676905} q-axis
  to_q  = {4.63399482930977,  0.0387883296526998, 0.00197933074735668} q-axis
  xtr_q = {0.275669319075036, 0.187924853846143,  0.170964423631031}   q-axis
  v_f denotes the field voltage.
The code uses
  xsig_s for xsig_0: armature leakage reactance
  xsig_r for xsig:   rotor leakage reactances
  r_s    for r_0:    armature (stator) resistance
  r_r    for r:      rotor resistances
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| SI.AngularFrequency | omega_nom | 2*pi*60 | nom ang frequency |
| SIpu.Reactance | x_d | 1.77 | syn reactance d-axis |
| SIpu.Reactance | x_q | 1.77 | syn reactance q-axis |
| SIpu.Reactance | xsig_s | 0.17 | leakage reactance stator |
| SIpu.Resistance | r_s | 0.005 | resistance stator |
| SIpu.Reactance | xsig_rd | {0.13, 0.035, 0.001} | leakage reactance rotor d-axis {f, D1, D2} |
| SIpu.Reactance | xsig_rq | {0.13, 0.035, 0.001} | leakage reactance rotor q-axis{Q1, Q2, Q3} |
| SIpu.Reactance | xm_d | {0.02, 0.04} | coupling-reactance d-axis |
| SIpu.Resistance | r_rd | {0.0011, 0.012, 0.03} | resistance rotor d-axis{f, D1, D2} |
| SIpu.Resistance | r_rq | {0.0011, 0.012, 0.03} | resistance rotor q-axis{Q1, Q2, Q3} |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Real | zr_d | ||
| Real | zx_d | ||
| Real | zr_q | ||
| Real | zx_q |
Contents
| Name | Description |
|---|---|
 z_matrixprotected |