modelBase
Base of a Stewart Platform
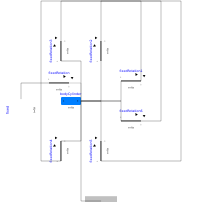
Extends from StewartPlatform.Icons.Base (Icon for 'Base' model), Disc (Cylindrical disc used to model the base and the platform).
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| StewartPlatform.Types.DiscParameters | discParameters (from Disc) | Parameters of the disc | |
| Direction | direction (from Disc) | Direction.down | Cylinder direction from x-y plane along z-axis |
| Boolean | useGlobalParameters | true | =true, if you want to use the base parameters defined in the 'gp' (GlobalParameters) object |
| StewartPlatform.Types.DiscParameters | base | Parameters of the base | |
| SI.Position[3] | basePos | {0, 0, 0} | Vector from world frame to base.frame_a resolved in world frame |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Interfaces.Frame_a | frame_a (from Disc) | Frame in the center of the disc | |
| Modelica.Mechanics.MultiBody.Interfaces.Frame_b[6] | frame_b (from Disc) | Frames where the joints are located |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.MultiBody.Parts.FixedRotation | fixedRotation1 (from Disc) | ||
| Modelica.Mechanics.MultiBody.Parts.FixedRotation | fixedRotation2 (from Disc) | ||
| Modelica.Mechanics.MultiBody.Parts.FixedRotation | fixedRotation3 (from Disc) | ||
| Modelica.Mechanics.MultiBody.Parts.FixedRotation | fixedRotation4 (from Disc) | ||
| Modelica.Mechanics.MultiBody.Parts.FixedRotation | fixedRotation5 (from Disc) | ||
| Modelica.Mechanics.MultiBody.Parts.FixedRotation | fixedRotation6 (from Disc) | ||
| Modelica.Mechanics.MultiBody.Parts.BodyCylinder | bodyCylinder (from Disc) | ||
| StewartPlatform.Components.GlobalParameters | gp | ||
| Modelica.Mechanics.MultiBody.Parts.Fixed | fixed | ||
| Modelica.Mechanics.MultiBody.Parts.FixedRotation | fixedRotation |