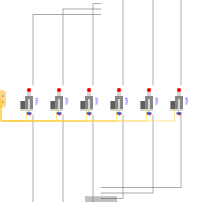
modelSixLegs
Set of six legs of a Stewart Platform appropiately connected, composed of electric cylinders and servo motors
Extends from StewartPlatform.Icons.SixLegs (Icon for 'SixLegs' model).
Parameters
| Type | Name | Default | Description |
|---|
| Universal joints |
| UniversalJointParameters[6] | universalJointParameters | gp.universalJointParameters | Parameters of the universal joints |
| Electric cylinders |
| ElectricCylinderParameters[6] | electricCylinderParameters | gp.electricCylinderParameters | Parameters of the electric cylinders |
| Servo motors |
| ServoMotorParameters[6] | servoMotorParameters | gp.servoMotorParameters | Parameters of the servo motors |
| Spherical joints |
| SphericalJointParameters[6] | sphericalJointParameters | gp.sphericalJointParameters | Parameters of the spherical joints |