modelTorqueController_SI_df_dt
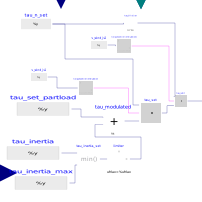
Extends from TransiEnt.Basics.Icons.Controller (Icon for controller).
Information
1. Purpose of model
Torque Controller with synthetic Inertia control depending on the rate of change of frequency (df/dt).
2. Level of detail, physical effects considered, and physical insight
Quasistationary model for real power simulation only.
3. Limits of validity
(Purely technical component without physical modeling.)
4. Interfaces
y: Modelica RealOutput
omega_is: input for angular velocity in rad/s
der_f_grid: input for the derivation of the frequency
P_el_pu: input for electric power in W
5. Nomenclature
H_e is the effective inertia
6. Governing Equations
(no equations)
7. Remarks for Usage
(no remarks)
8. Validation
Validated according to reference stated below.
9. References
Wu, Lei: "Towards an Assessment of Power System Frequency Support From Wind Pland - Modeling Aggregate Inertial Response"
10. Version History
Model created by Rebekka Denninger (rebekka.denninger@tuhh.de) on June 21 2016
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | limitsAtInit | true | = false, if limits are ignored during initialization |
| Real | k_turbine | Turbine control constant | |
| Real | J | Wind turbine moment of inertia | |
| Real | lambdaOpt | Optimal tip speed ratio | |
| Modelica.Units.SI.Density | rho | Density | |
| Modelica.Units.SI.Length | radius | Rotor Radius | |
| Real | cp_opt | Optimal capacity factor | |
| SI.Torque | tau_n | ||
| SI.Torque | tau_start | K_start*tau_n | Start value of torque |
| Real | K_start | -0.05 | Factor of torque at startup in pu |
| SI.Time | T_torqueControl | 1 | Time Constant |
| SI.Velocity | v_cutIn | Cutin wind speed | |
| SI.Velocity | v_fullLoad | Nominal wind speed | |
| Advanced | |||
| Boolean | strict | false | = true, if strict limits with noEvent(..) |
| Controller › Torque | |||
| Modelica.Blocks.Types.SimpleController | controllerType_T | .Modelica.Blocks.Types.SimpleController.PI | Type of controller |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| TransiEnt.Basics.Interfaces.General.AngularVelocityIn | omega_is | Input for angular velocity | |
| Modelica.Blocks.Interfaces.RealOutput | y | ||
| Modelica.Blocks.Interfaces.RealInput | der_f_grid | ||
| TransiEnt.Basics.Interfaces.Electrical.ElectricPowerIn | P_el_pu |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Velocity | v_wind | Wind velocity | |
| Real | tau_set_pu | ||
| Modelica.Blocks.Logical.Hysteresis | torqueControllerDisabled | ||
| Modelica.Blocks.Logical.Switch | tau_set | ||
| Modelica.Blocks.Sources.RealExpression | tau_set_partload | ||
| Modelica.Blocks.Math.MultiSum | tau_modulated | ||
| Modelica.Blocks.Sources.RealExpression | tau_inertia | ||
| Real | H_e | Effective inertia | |
| Modelica.Blocks.Sources.RealExpression | v_wind_is1 | ||
| Modelica.Blocks.Math.Min | tau_inertia_set | ||
| Modelica.Blocks.Sources.RealExpression | tau_inertia_max | ||
| Modelica.Blocks.Nonlinear.Limiter | limiter | ||
| Modelica.Blocks.Sources.RealExpression | v_wind_is2 | ||
| Modelica.Blocks.Logical.Hysteresis | torqueControllerDisabled1 | ||
| Modelica.Blocks.Math.Gain | tau_friction | ||
| Modelica.Blocks.Sources.RealExpression | tau_n_set | ||
| Modelica.Blocks.Logical.Switch | tau_set2 |