blockFirstOrder_variableDamping
First order transfer function block (= 1 pole) with variable damping
Extends from Modelica.Blocks.Interfaces.MISO (Multiple Input Single Output continuous control block).
Information
1. Purpose of model
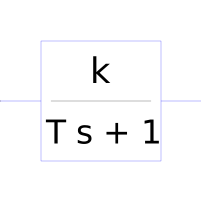
This blocks defines the transfer function between the input u and the output y (element-wise) as first order system with variable damping:
               k
     y = ------------ * u
            T * s + 1
2. Level of detail, physical effects considered, and physical insight
No physical effects considered.
3. Limits of validity
(no remarks)
4. Interfaces
(no remarks)
5. Nomenclature
u[1]: signal input
u[2]: damping input
6. Governing Equations
(no equations)
7. Remarks for Usage
(no remarks)
8. Validation
(no remarks)
9. References
(no remarks)
10. Version History
Function created by Paul Kernstock (paul.kernstock@tuhh.de) August 2015
Revised by Lisa Andresen (andresen@tuhh.de), Aug 2015
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Integer | nin (from MISO) | 1 | Number of inputs |
| Real | k | 1 | Gain |
| Initialization | |||
| Modelica.Blocks.Types.Init | initType | Modelica.Blocks.Types.Init.NoInit | Type of initialization (1: no init, 2: steady state, 3/4: initial output) |
| Real | y_start | 0 | Initial or guess value of output (= state) |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| RealInput[nin] | u (from MISO) | Connector of Real input signals | |
| RealOutput | y (from MISO) | Connector of Real output signal |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Units.SI.Time | T | u[2] | Variable time Constant |