modelCollisionTangential
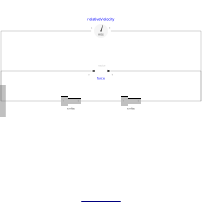
Extends from Modelica.Mechanics.MultiBody.Interfaces.PartialTwoFrames (Base model for components providing two frame connectors + outer world + assert to guarantee that the component is connected).
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Units.SI.CoefficientOfFriction | mue | 0.4 | |
| Modelica.Units.SI.Velocity | vd | 0.01 | |
| Modelica.Mechanics.MultiBody.Types.Axis | n_x | {1.0, 0.0, 0.0} | |
| Modelica.Mechanics.MultiBody.Types.Axis | n_y | {0.0, 1.0, 0.0} |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Interfaces.Frame_a | frame_a (from PartialTwoFrames) | Coordinate system a fixed to the component with one cut-force and cut-torque | |
| Interfaces.Frame_b | frame_b (from PartialTwoFrames) | Coordinate system b fixed to the component with one cut-force and cut-torque | |
| Modelica.Blocks.Interfaces.RealInput | fN | Connector of Real input signal |
Components
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Units.SI.Velocity | v_x | n_x*relativeVelocity.v_rel | |
| Modelica.Units.SI.Velocity | v_y | n_y*relativeVelocity.v_rel | |
| Modelica.Units.SI.Velocity | v_t | sqrt(v_x^2 + v_y^2) | |
| Modelica.Units.SI.Force | f | ||
| Modelica.Mechanics.MultiBody.Joints.Prismatic | prismaticX | ||
| Modelica.Mechanics.MultiBody.Joints.Prismatic | prismaticY | ||
| Modelica.Mechanics.MultiBody.Forces.Force | force | ||
| Modelica.Mechanics.MultiBody.Sensors.RelativeVelocity | relativeVelocity |