modelDoublePendulumInverse

Multibody model of inverse crane trolley
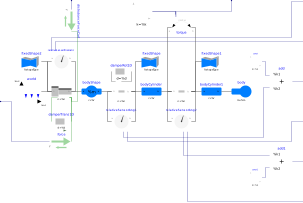
Diagram of DoublePendulumInverse

Extends from DoublePendulum (Multibody model of crane trolley).

Information

Multibody model of a simple inverted double pendulum system. This physical model is used in various models and functions of the library e.g. for linearization or as a base for linear controller design. The mdel is the same as in Modelica_Controller.Examples.Components.DoublePendulum but with different initial values because the initial values are used as a working point for linearization.

Parameters

TypeNameDefaultDescription
Modelica.Units.SI.Massm_trolley (from DoublePendulum)5Mass of trolley
Modelica.Units.SI.Massm_load (from DoublePendulum)20Mass of load on 2nd arm
Modelica.Units.SI.Lengthlength (from DoublePendulum)2Total length of double pendulum (i.e. length of each arm = length/2)
Modelica.Units.SI.Positions_start (from DoublePendulum)0.0Initial position of trolley relative to world
Modelica.Units.SI.Velocityv_start (from DoublePendulum)0.0Initial velocity of trolley relative to world
Modelica.Units.SI.Anglephi1_start (from DoublePendulum)-80.0/180*piInitial rotation angle of 1st arm relative to trolley
Modelica.Units.SI.Anglephi2_start (from DoublePendulum)10Initial rotation angle of 2nd arm relative to 1st arm
Modelica.Units.SI.AngularVelocityw1_start (from DoublePendulum)0.0Initial angular velocity of 1st arm relative to trolley
Modelica.Units.SI.AngularVelocityw2_start (from DoublePendulum)0.0Initial angular velocity of 2nd arm relative to 1st arm
Modelica.Units.SI.RotationalDampingConstantd (from DoublePendulum)0Damping constant for revolute joint of 1st arm
Realpi (from DoublePendulum)Modelica.Constants.pi
BooleancartDisturbancefalseTrue, if cart disturbance should be enabled
BooleanbodyDisturbancefalseTrue, if body disturbance should be enabled

Connectors

TypeNameDefaultDescription
Modelica.Blocks.Interfaces.RealInputu (from DoublePendulum)
Modelica.Blocks.Interfaces.RealOutputs (from DoublePendulum)
Modelica.Blocks.Interfaces.RealOutputv (from DoublePendulum)
Modelica.Blocks.Interfaces.RealOutputphi (from DoublePendulum)
Modelica.Blocks.Interfaces.RealOutputw (from DoublePendulum)
Modelica.Blocks.Interfaces.RealOutputphi1 (from DoublePendulum)
Modelica.Blocks.Interfaces.RealOutputw1 (from DoublePendulum)
Modelica.Blocks.Interfaces.RealInputdist
Modelica.Blocks.Interfaces.RealInputdist2

Components

TypeNameDefaultDescription
Modelica.Mechanics.MultiBody.Sensors.RelativeSensorrelativeSensorPrismatic (from DoublePendulum)
Modelica.Mechanics.MultiBody.Sensors.RelativeSensorrelativeSensorAng1 (from DoublePendulum)
Modelica.Mechanics.MultiBody.Sensors.RelativeSensorrelativeSensorAng2 (from DoublePendulum)
Modelica.Mechanics.MultiBody.Worldworld (from DoublePendulum)
Modelica.Mechanics.MultiBody.Joints.Prismaticprismatic (from DoublePendulum)
Modelica.Mechanics.MultiBody.Joints.Revoluterevolute1 (from DoublePendulum)
Modelica.Mechanics.MultiBody.Joints.Revoluterevolute2 (from DoublePendulum)
Modelica.Mechanics.MultiBody.Parts.BodyShapebodyShape (from DoublePendulum)
Modelica.Mechanics.MultiBody.Parts.Bodybody (from DoublePendulum)
Modelica.Mechanics.MultiBody.Parts.BodyCylinderbodyCylinder (from DoublePendulum)
Modelica.Mechanics.MultiBody.Parts.BodyCylinderbodyCylinder1 (from DoublePendulum)
Modelica.Mechanics.Translational.Components.DamperdamperTrans1D (from DoublePendulum)
Modelica.Mechanics.Rotational.Components.DamperdamperRot1D (from DoublePendulum)
Modelica.Mechanics.Translational.Sources.Forceforce (from DoublePendulum)
Modelica.Blocks.Sources.Constantconst (from DoublePendulum)
Modelica.Blocks.Math.Addadd (from DoublePendulum)
Modelica.Blocks.Math.Addadd1 (from DoublePendulum)
Modelica.Blocks.Sources.Constantconst1 (from DoublePendulum)
Modelica.Mechanics.Translational.Sources.ForcedistrubanceForceCart
Modelica.Mechanics.MultiBody.Forces.Torquetorque
Modelica.Blocks.Sources.ConstantconstZero
Modelica.Mechanics.MultiBody.Visualizers.FixedShapefixedShape
Modelica.Mechanics.MultiBody.Visualizers.FixedShapefixedShape1
Modelica.Mechanics.MultiBody.Visualizers.FixedShapefixedShape2