modelASM_ctrlAv
AC asynchronous machine, current controlled with average inverter
Extends from Modelica.Icons.Example (Icon for runnable examples).
Information
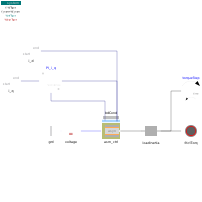
Field oriented control of asynchronous machine with time-average inverter. The first component of i_dq controls 'field', the second controls 'torque' at constant 'field'.
On-load steady-state start with torque-increase at 3 s, load-step 6 s and field-increase at 8 s.See for example:
  asm_ctrl.motor.tau_el
  asm_ctrl.motor.w_el
  asm_ctrl.motor.vPhasor
  asm_ctrl.motor.slip
Check vPhasor[1] < 1.
The time-average inverter produces a desired voltage proportional to vPhasor[1] even if vPhasor[1] > 1. For a time-resolved converter this corresponds to overmodulation.
Components
| Type | Name | Default | Description |
|---|---|---|---|
| PowerSystems.System | system | ||
| PowerSystems.AC1ph_DC.Nodes.GroundOne | grd | ||
| PowerSystems.AC1ph_DC.Sources.DCvoltage | voltage | ||
| PowerSystems.AC3ph.Drives.ASM_ctrl | asm_ctrl | ||
| PowerSystems.Common.Thermal.BdCondV | bdCond | ||
| PowerSystems.Mechanics.Rotational.Rotor | loadInertia | ||
| PowerSystems.Mechanics.Rotational.FrictionTorque | frictTorq | ||
| Modelica.Mechanics.Rotational.Sources.TorqueStep | torqueStep | ||
| PowerSystems.Blocks.Signals.Transient | i_q | phase of modulation signal | |
| PowerSystems.Blocks.Signals.Transient | i_d | phase of modulation signal | |
| Modelica.Blocks.Continuous.LimPID | PI_i_q |