packageReferenceSignals
Library of models to define reference trajectories
Extends from StewartPlatform.Icons.ReferenceSignals (Icon for 'ReferenceSignals' package).
Contents
| Name | Description |
|---|---|
 InverseKinematic | The outputs are the six leg lengths required to have the input pose |
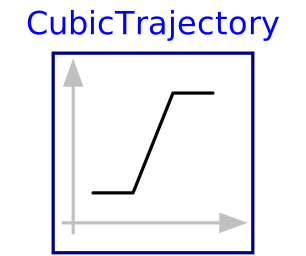 CubicTrajectory | The outputs are the position and orientation of the platform to follow a line with a cubic eqution of motion |
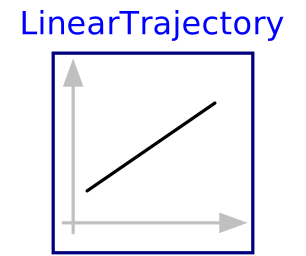 LinearTrajectory | The outputs are the position and orientation of the platform to follow a linear trajectory with constant speed |
| PartialTrajectoryModel | This model collects all the common parameters and interfaces of the trajectory models |
 Paths | Library of reference paths |
 StepTrajectory | Instant switch from initial pose to final pose |
 Switch | Switch between two or more Pose signals |
 Switch2 | Switch between two or more Pose signals, the definition of the swith times is not required |
 TrapezoidalTrajectory | The outputs are the position and orientation of the platform to follow a line with a trapezoidal velocity profile (constant orientation) |