modelMinimalBrakes
Simple proportional (constant gain) braking model for 4 wheeled vehicles
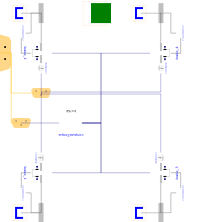
Extends from VehicleInterfaces.Icons.Brakes (Icon for a brakes subsystem), VehicleInterfaces.Brakes.Interfaces.TwoAxleBase (Interface definition for the brakes on a 4 wheeled vehicle).
Information
Brakes subsystem model that uses the driver brakePedalPosition signal to determine the brake torque demand being requested by the driver.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| SI.Torque | maxTorque | 1000 | Maximum combined brake torque (for all brakes together) |
| Advanced › Only for 1D brakes | |||
| Boolean | usingMultiBodyChassis (from Base) | false | = true, if connecting to a MultiBody chassis |
Connectors
| Type | Name | Default | Description |
|---|---|---|---|
| Modelica.Mechanics.Translational.Interfaces.Flange_a | brakePedal (from Base) | Brake pedal connection (optional) | |
| VehicleInterfaces.Interfaces.ControlBus | controlBus (from Base) | Control signal bus | |
| Modelica.Mechanics.MultiBody.Interfaces.FlangeWithBearing | wheelHub_1 (from TwoAxleBase) | Front left wheel | |
| Modelica.Mechanics.MultiBody.Interfaces.FlangeWithBearing | wheelHub_2 (from TwoAxleBase) | Front right wheel | |
| Modelica.Mechanics.MultiBody.Interfaces.FlangeWithBearing | wheelHub_3 (from TwoAxleBase) | Rear left wheel | |
| Modelica.Mechanics.MultiBody.Interfaces.FlangeWithBearing | wheelHub_4 (from TwoAxleBase) | Rear right wheel |