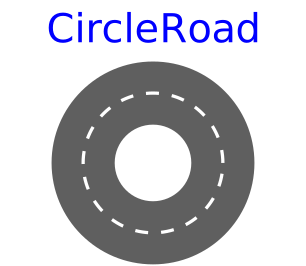
modelCircleRoad
Circular road (perpendicular to world z-axis)
Extends from VehicleInterfaces.Roads.Interfaces.Base (Base model for all roads).
Information
The road is a circle described by "radius" and "width". The road surface parameters are defined as:
s: arc length along circle
w: lateral displacement of road, perpendiular to circle
The point s = 0, w = 0 has position vector r = {0, -radius, 0};
The functions are defined in such a way that Dymola inlines all the functions. As a result, it is easy to get derivatives of the functions.
Parameters
| Type | Name | Default | Description |
|---|---|---|---|
| Boolean | animation | true | = true, if road shall be visualized |
| SI.Radius | radius | Radius of road | |
| SI.Length | width | Width of road | |
| Real | mu | Friction coefficient of road | |
| Modelica.Mechanics.MultiBody.Types.Color | roadColor | {255, 0, 0} | Color of road |
| Real | pi | Modelica.Constants.pi |
Contents
| Name | Description |
|---|---|
 r_middleprotected | Determine point on road in the middle of the circle (w=0 |
 circlePositionprotected | Determine point on road |
 constantOffsetprotected | Determine offset from road centre line |
 circleNormalprotected | Determine unit normal on road, given road surface parameters |
 circleHeadingDirectionprotected | Determine unit heading direction on road |
 circleFrictionCoefficientprotected | Determine friction coefficient at point on road |